Automation & Robotics

Robotic setup in minutes, not hours

Spatial AI that gives industrial robots the 3D awareness they need for maintenance and repair.

Robots are ready. Setup is the bottleneck.

Painting, de-painting, welding, blasting, and inspection are labor-intensive, hazardous, and dependent on skilled technicians. Robots can take this work on, but every asset enters the work-cell in a different position or condition, so the robot is set up again for each job.

The result: much of the efficiency robotics promises is lost before work begins.
Every job starts with manual setup

  1. Measure the asset
  2. Re-establish coordinates
  3. Reprogram the robot
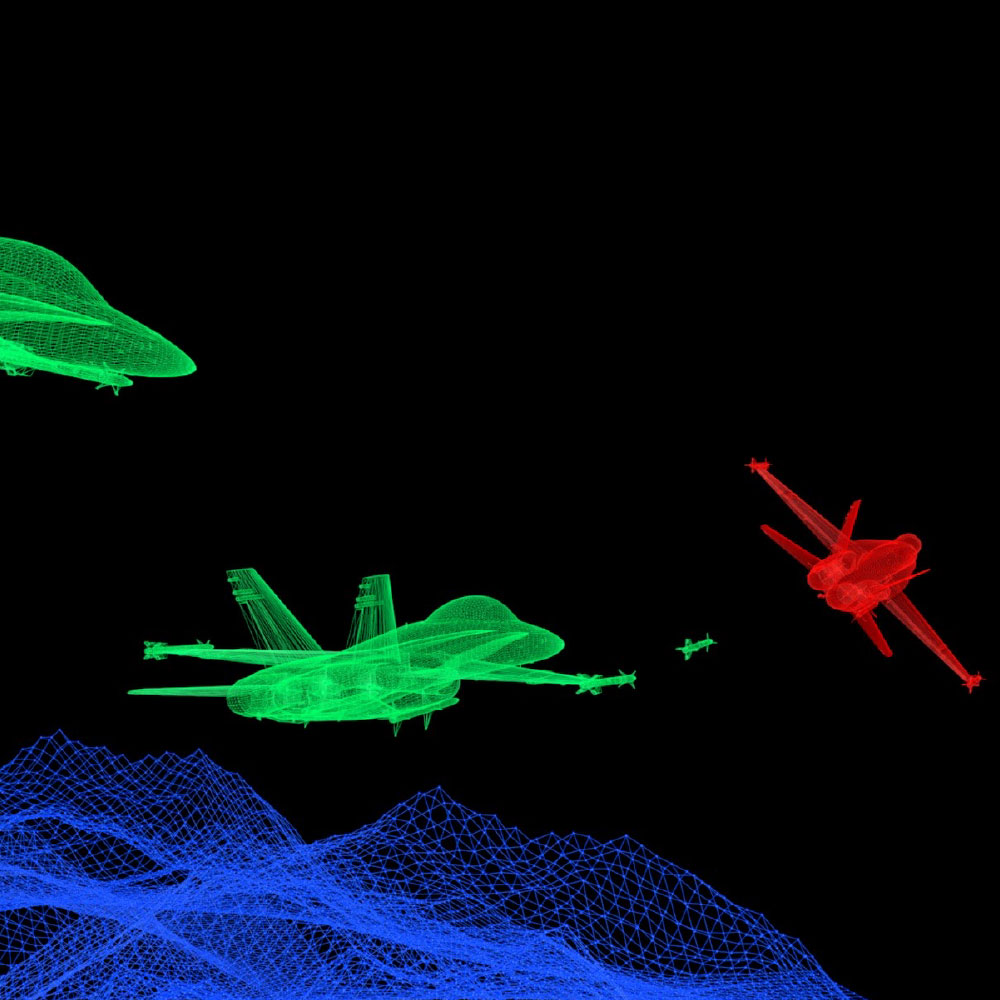
SPIDER segments a work-cell: aircraft, robot arms, keep-out zones and regions of interest highlighted in 3D
What SPIDER seesRegions of interest, keep-out zones and the localized asset, straight from the 3D digital twin, with no fiducials on the part.

What every robot needs to know

  • 3D digital twin

    A CAD model or generated 3D model of the asset.

  • Part localization

    Exact position and orientation in the work-cell.

  • Regions of interest

    The specific surfaces that need work.

  • Keep-out zones

    Boundaries for collision-free path planning.

Meet SPIDER Robotics

Spatial Intelligence and Dynamic Extended Reality

SPIDER delivers the spatial data robots need automatically, with no markers, fiducials, or manual coordinate programming.

Operators select the area that needs work on the asset or its digital twin. SPIDER turns that selection into robot-ready coordinates.

  • Computer Vision

    Sees and maps the asset in 3D

  • AI / ML

    Recognizes and localizes parts

  • Extended Reality

    Intuitive operator selection

How it works

  1. Capture

    Generate the 3D digital twin from a COTS device capture or existing CAD.

  2. Register

    Recognize the asset in the work-cell with no markers.

  3. Localize

    Pinpoint parts and regions of interest in real time.

  4. Convert

    Map the operator’s XR selection into robot space.

  5. Transfer

    Send coordinates to the robot controller over encrypted APIs.

Built for demanding environments

  • Robot-agnostic

    Integrates with your existing robots and controller software through documented APIs.

  • Secure and air-gapped

    Runs fully on-premises. No cloud or internet connection required.

  • Markerless

    Nothing to attach to each vehicle or component before work starts.

  • Field-proven

    Deployed in defense aircraft maintenance and industrial work-cells today.

One platform, many processes

The same spatial workflow supports the full range of maintenance and repair tasks. One integration covers the labor-intensive and hazardous jobs across the facility.

  • Painting
  • De-painting
  • Welding
  • Blasting
  • Grinding
  • Inspection
  • Material handling
  • Repair

Ready to accelerate your robotic workflows?

Tell us about your work-cell and we will follow up.

Critical Use Cases

CRITICAL USE CASE

Robot Path Planning

SPIDER builds a real-time 3D map of the work area, segments objects (3D-SAM), and exports transforms to the robot, which plans and continuously re-plans a collision-free path around a changing floor.

CRITICAL USE CASE

Robotic Workflow Automation

Working from SPIDER’s shared spatial data, the robot positions itself and simulates its next move for review. The technician approves each critical step before it executes, keeping operators out of hazardous, repetitive work.

CRITICAL USE CASE

Robot Learning from Humans

The robot observes a technician performing a task and learns to mimic it, extending automation to hazardous, remote, or highly repeatable work without hand-coding each motion.

Image: REUTERS/Stringer

CRITICAL USE CASE

Collaborative Robotic Environments

SPIDER creates dynamic training environments for human-robot collaboration. Trainees interact with real-time 3D models and sensor feeds, simulating robotic tasks in complex scenarios to enhance skills and safety.